Agibot Psi-R2.5 Embodied Foundation Model Uses Paired Human-Robot Data for One-Shot Imitation
Agibot (Lingchu Intelligence) released Psi-R2.5, a new embodied foundation model that introduces a training pipeline based on paired human-robot data (Pair Data) instead of the raw large-scale human videos used previously. After a single human demonstration, the model can reproduce a task through context learning without retraining or fine-tuning. The new approach aims to streamline the conversion of human data into robot-executable trajectories, addressing data scarcity and embodiment gap issues.
Coverage timeline
机器之心机器之心
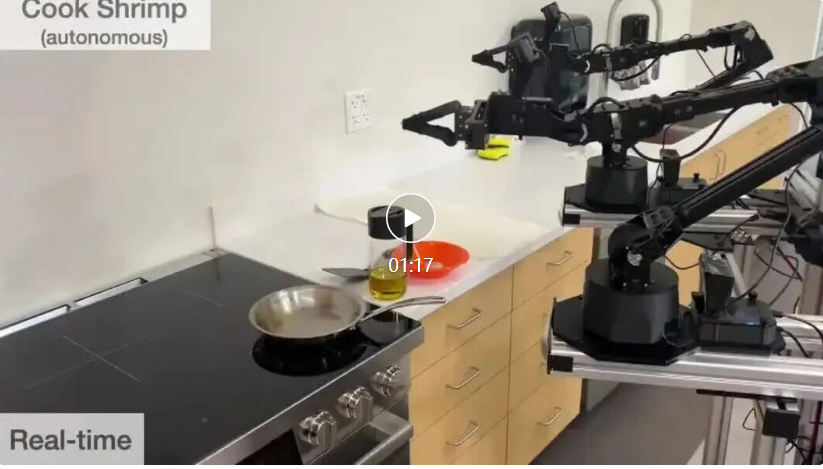
编辑|山辉 两年前,一段机器人炒虾的视频在网上爆火。 视频中的机械臂一手端锅、一手拿铲,把虾翻炒后倒进碗里,看起来已经很像一个熟练的厨房帮手。 但机器人学会这套动作并不轻松。研究人员需要先亲自操控机器人完成任务,反复采集真机示范,再通过模仿学习让机器人逐渐学会独立执行。 对于一个固定任务,大约要采集 50 次这样的示范 。 如今,灵初智能在相似的任务中,展示了机器人学习的另一种可能。在这组演示里, 人只需要示范一遍,无需重新训练或微调模型,机器人就能把这段操作作为类似 Prompt 的上下文,尝试完成新任务。 人类示范「准备配菜 — 青椒下锅 — 龙虾下锅」三步流程后,Psi-R2.5 通过 In-Context Learning 按顺序复现任务,无需重新训练模型。 同样是炒菜,两年前关注的是机器人「会不会」,现在灵初更关注机器人「 怎么学 」。 对人来说,拿起锅铲,翻动食材,几乎都是下意识完成的。那能不能跳过一遍遍的采集真机数据,直接把人类的操作经验拿来训练机器人? 灵初此前已经在沿着这条路前进。 四月发布的 Psi-R2 和 Psi-W0 将十万小时规模的人类数据用于预训练,并通过 Psi-W0 和强化学习,把人手轨迹进一步优化成机器人能够执行的轨迹。但这意味着,Policy 与 World Model 需要反复 rollout,轨迹还要继续用强化学习微调,整个转换链路依然繁琐。 现在,灵初智能正式发布新一代具身基础模型 Psi-R2.5。 这一次,团队没有继续把重点停留在「十万小时人类数据」上,而是开始处理数据规模起来之后的两个新问题: 哪些数据真正有价值,以及怎样让这些人类数据更顺畅地进入机器人的训练过程。 项目演示与完整技术博客: Scaling Pair Data for Embodied Intelligence https://www.psibot.ai/scaling-pair-data-for-embodied-intelligence-zh/ 在数据转换方面有一个关键变化, 既然从人类数据到机器人数据的转换很麻烦,能不能反过来,先从本来就能执行的真实机器人数据出发? 答案落在了 Pair Data 上。 Scaling Pair Data:让人类数据真正进入机器人训练 为什么不能直接把人类视频拿来训练机器人?核心还是 Embodiment Ga
Related stories
Prime Intellect releases prime-rl v0.10.0 with IPO loss as default
Prime Intellect released prime-rl v0.10.0 and verifiers v0.4.0. The update introduces the new RL algorithm IPO as the default, designed for async RL stability, along with performance improvements and new model support.
1 reports · 1 sources
StepFun Releases 321B-Parameter Quantized Step-5-Preview-NVFP4 on Hugging Face
StepFun has released Step-5-Preview-NVFP4, a 321B-parameter quantized variant of its Step-5-Preview model, on Hugging Face. The model is available under the stepfun-ai organization and was updated 36 minutes ago.
1 reports · 1 sources
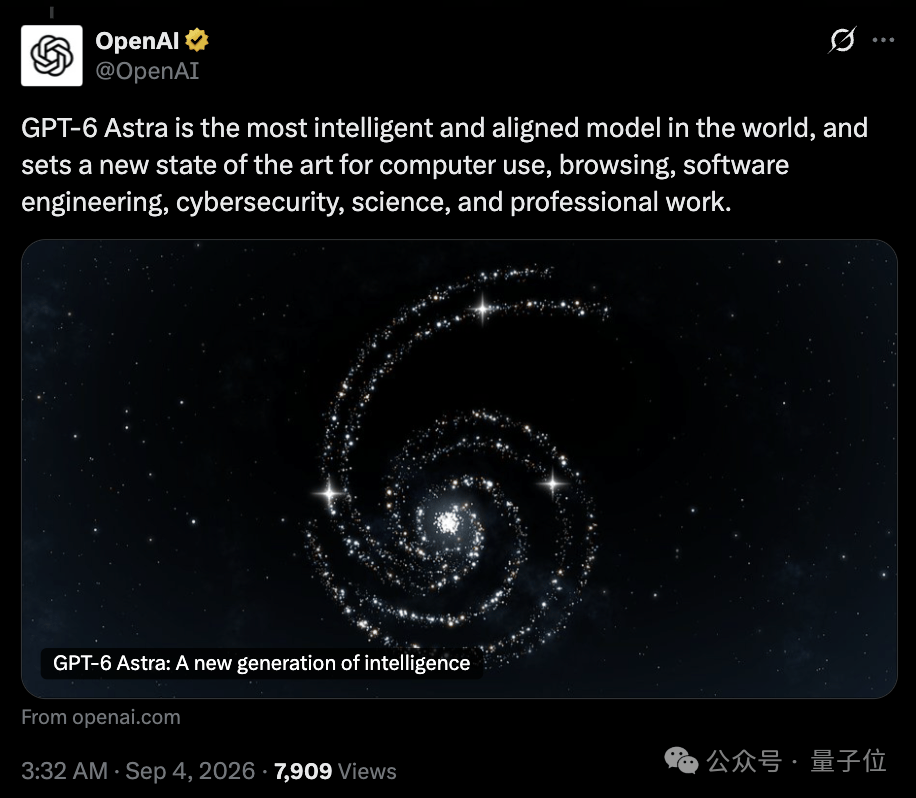
OpenAI launches GPT-6 Astra, claims world's best computer use model
OpenAI announced GPT-6 Astra, its next-generation model focused on computer and browser use, claiming it is the world's most intelligent and aligned model. The company stated Astra was built on its largest training run using over 100,000 GPUs at the Stargate facility, and in tests it outperformed humans in tasks like booking DMV appointments and searching job listings. OpenAI president Greg Brockman declared 'Welcome to the AGI era,' though the model's capabilities and limitations are still being assessed by developers.
23 reports · 9 sources515 points · 162 comments
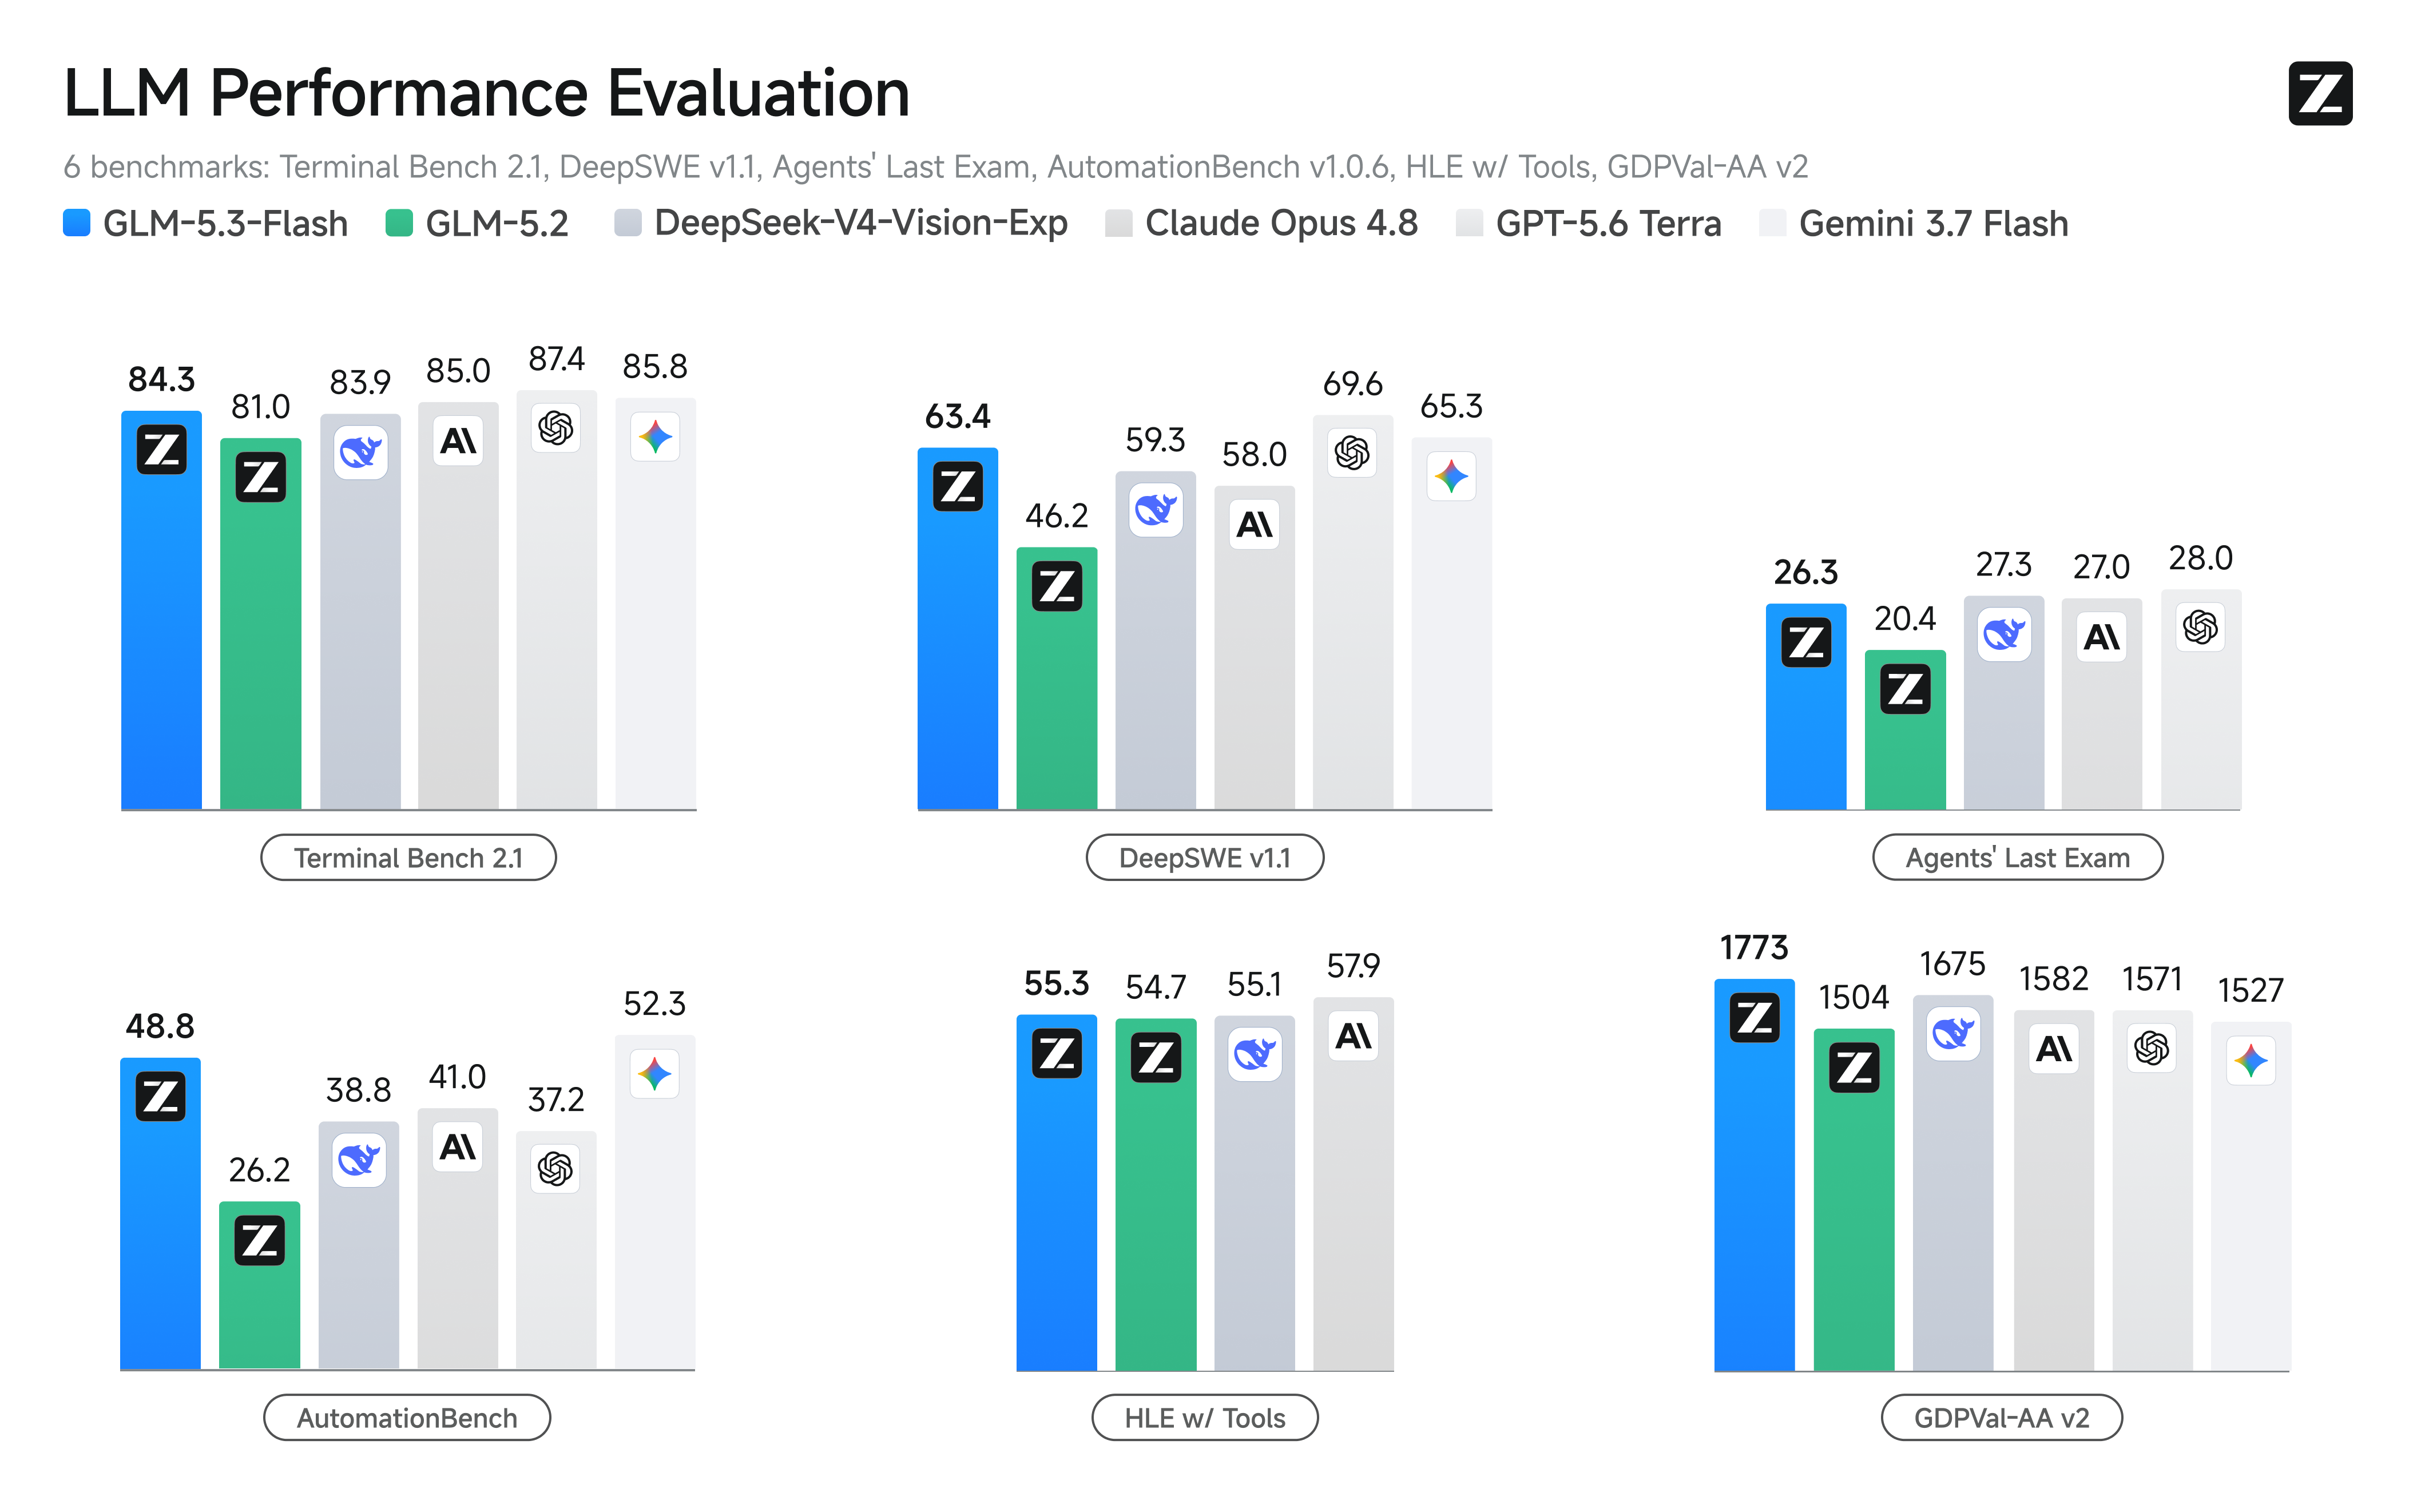
Zhipu AI open-sources GLM-5.3-Flash, a 320B multimodal model priced at 1/40 of Claude Opus 4.8
Zhipu AI released and open-sourced GLM-5.3-Flash, the first natively multimodal model in the GLM-5 series, with 320B total parameters (18B active). It scores 57 on the Artificial Analysis Intelligence Index, matching Claude Opus 4.8, and is priced at one-tenth of GLM-5.3, or one-fortieth of Opus 4.8. The model uses a hybrid sparse and linear attention architecture, runs on domestic Chinese chips, and was tested anonymously as Ox-Alpha on OpenRouter and OpenCode.
8 reports · 5 sources1126 points · 573 comments
News updates every hour. Subscribe in your RSS reader to get new stories automatically.
Subscribe