FAME: Flow-Driven Multi-Anchor Exploration for Active 3D Mapping Accepted as NeurIPS 2026 Spotlight
Researchers from Tianjin University and Hefei University of Technology proposed FAME, a flow-driven multi-anchor exploration method for open-environment active 3D mapping. Unlike traditional methods that predict a single exploration goal, FAME uses Conditional Flow Matching to generate multiple possible goals, combined with path planning, exploration mode clustering, and hierarchical selection. The paper was accepted as a Spotlight at NeurIPS 2026, with 292 out of 7,900 accepted papers selected for this distinction.
Coverage timeline
机器之心机器之心
该论文第一作者为李阳,天津大学人工智能学院2026级博士生,师从韩亚洪教授,主要研究方向为具身智能,相关研究成果发表于 CVPR、NeurIPS、TPAMI 等国际顶级会议及期刊。本研究由天津大学与合肥工业大学团队合作完成。实验室主页: https://tjumm.github.io/ 想象一下,一台机器人正在探索一栋从未进入过的建筑。 它已经走过一段走廊,眼前出现几个不同方向的通道。但由于视野有限,机器人并不知道哪条路通向更大的空间,哪条路可能是死胡同,也不知道尚未探索的区域究竟是什么结构。 这时,它该往哪里走? 目前,许多学习型主动三维建图方法,往往只预测一个长期探索目标,再据此规划路径。 问题在于: 当机器人对未知环境了解得还不够多时,为什么一定要提前押注一个方向? 针对这一问题,天津大学与合肥工业大学研究团队提出了 FAME(Flow-driven Anchor-based Multimodal Exploration) 。与传统方法只预测一个目标不同,FAME 利用 Conditional Flow Matching 同时生成多个可能的探索目标,再结合路径规划、探索模式聚类和分层选择,帮助机器人在未知环境中找到更合适的探索路线。 目前,该研究成果已被 NeurIPS 2026 接收,并进一步入选 Spotlight(亮点论文) 。本届会议共录用 7,900 篇论文,其中 292 篇 入选 Spotlight,约占录用论文的 3.7% 。 论文标题: All Roads Lead to Rome: Flow-driven Multi-Anchor Exploration for Open-Environment Active 3D Mapping 项目主页:https://vollichor.github.io/FAME/ 论文链接: https://arxiv.org/abs/2609.36889 从「只选一条路」,到保留多种探索可能 主动三维建图(Active 3D Mapping) 不仅要求机器人根据观测恢复环境的三维结构,还需要主动决定下一步去哪里采集信息,争取用更少的运动和观测代价,重建尽可能完整的场景。 然而,机器人能够观察到的始终只是环境的一部分。 即使两个场景的局部结构看起来相似,尚未探索的区域也可能完全不同。 如果模型只根据过去学到的经验预
Related stories
Fudan, Tencent Hunyuan, Tsinghua Release ExplorationBench to Test AI Rule Discovery
Fudan University, Tencent Hunyuan, and Tsinghua University released ExplorationBench, a benchmark measuring how AI systems discover rules in unfamiliar environments. It includes two altered 'alien worlds'—the programming language AlienCode and the logic proof system AlienLogic—where models must learn rules through trial and error. Results showed that without environment feedback, scores remained low (max 11.0%), while autonomous exploration led to high scores (up to 89.0%).
2 reports · 1 sources
Stanford's OpenWAM framework isolates design choices in world-action models
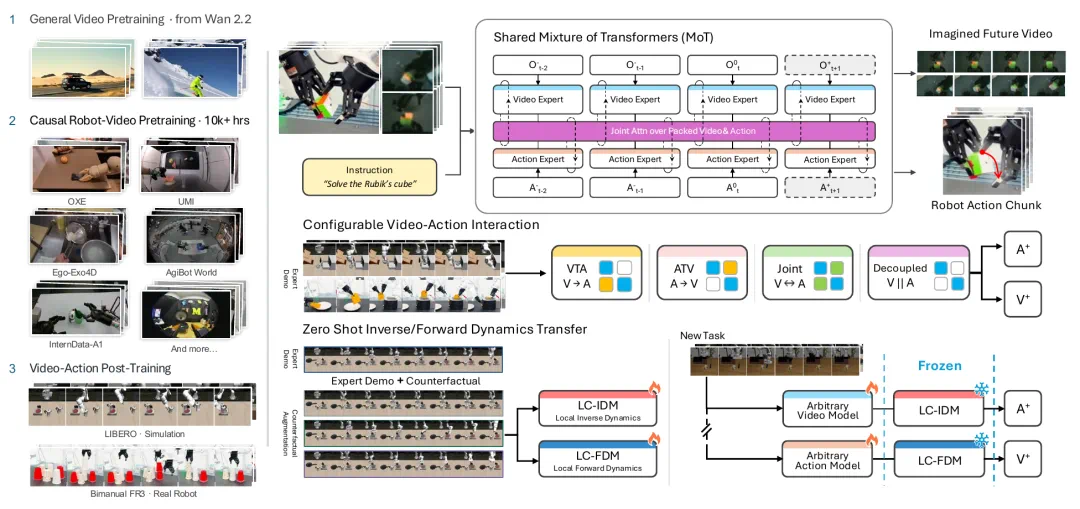
Stanford researchers led by Li Fei-Fei, Jiajun Wu, and Ehsan Adeli released OpenWAM, an open framework for composable world-action models, aiming to systematically isolate which design choices drive performance gains. The release follows Black Forest Labs' open-source FLUX 3 Action, a 7B world-action model that surpassed Cosmos 3 Nano on Nvidia's RoboLab-120 leaderboard with less than half the parameters.
VisInteract: Interactive Text-to-Visualization for Imperfect Queries, NeurIPS 2026 Spotlight
Researchers from Hong Kong Polytechnic University and ByteDance propose VisInteract, a new paradigm for dynamic interactive text-to-visualization that handles imperfect user queries. They introduce VisInteract-Bench, a benchmark acknowledging ambiguous, incomplete, or erroneous inputs, and Vis-MCTS, a Monte Carlo tree search-based method that branches and backtracks between data retrieval, chart generation, and clarification. The work was accepted as a Spotlight paper at NeurIPS 2026 (292 out of 30,709 submissions).
SAGE topological guidance mitigates long-horizon reasoning biases, NeurIPS 2026
Researchers from Virginia Tech, UW-Madison, and Dartmouth propose SAGE, a method that uses symbolic closure analysis and topological guidance to mitigate exploration and accumulation biases in long-horizon reasoning. Evaluated on 12 benchmarks across 7 model families, SAGE outperforms compared post-training methods; on Andrews–Curtis instances, Qwen3's Lean verification pass rate is nearly 8 times that of the base model. The paper is accepted at NeurIPS 2026.
News updates every hour. Subscribe in your RSS reader to get new stories automatically.
Subscribe