RAX: Harvard, Berkeley, NVIDIA Introduce Online Exploration Scaling for Robot Learning, Outperforming SOTA by 37.4 Points on Average
Researchers from Harvard, NVIDIA, UC Berkeley, MIT, and Stanford proposed RAX (Robot Agent eXploration), which introduces scaling online exploration to robot learning. RAX uses a general coding agent to connect directly to a robot's perception and control interfaces, enabling the robot to gain experience through exploration and write successful decisions as executable programs, accumulating reusable skills. With frozen model parameters, RAX outperforms previous state-of-the-art models by an average of 37.4 percentage points across five simulation benchmarks: RoboDojo, BEHAVIOR-1K, HumanoidArena, DexJoCo, and LIBERO-Pro.
Coverage timeline
机器之心机器之心
机器人领域已经轰轰烈烈地 Scaling 了好几年。 更多遥操数据、更大的模型,VLA 和 WAM 在实验室中不断刷新机器人能力的上限。数据越采越多,模型越做越大,到了实际生产部署,具身智能依然绕不开那个老大难问题:换一台机器人、换一个工作环境,还要重新投入多少人力、数据和算力? 成千上万小时的预训练,仍未让全新真实机器人上的零样本稳健部署成为常态。新本体需要重新采集数据、微调策略;场景和任务变了,又要继续适配。企业希望机器人尽快进入生产现场,研发团队却常常还在为下一轮数据采集和训练做准备。 所谓具身智能的 GPT 时刻,以及遥操作扩展带来人力与资源的无底洞,是不是忽略了智能真正的来源? 与人类类似,机器人应当通过不断的在线探索,扩展积累经验,通过 测试时扩展实现自我进化(self-improve) 。 来自哈佛大学、英伟达、加州大学伯克利分校、麻省理工学院和斯坦福大学的研究团队提出 RAX(Robot Agent eXploration),将 Scaling Online Exploration 带入机器人学习。通用 Coding Agent 直接连接机器人的感知与控制接口,通过探索获得经验,将成功决策写成可执行程序,再积累为可以持续复用的技能。 论文: Scaling Online Exploration for Robot Agents 项目主页与实验 session: https://robot-agent-exploration.com/ 论文全文: https://arxiv.org/abs/2610.22496 开源代码: https://github.com/robot-agent-exploration/rax Skill Library: https://github.com/robot-agent-exploration/skills-lib 完整实验记录:https://huggingface.co/datasets/robot-agent-exploration/robot-session-logs 模型参数保持冻结,机器人能力随着探索持续增长 。在 RoboDojo、BEHAVIOR-1K、HumanoidArena、DexJoCo 和 LIBERO-Pro 五大仿真基准上,RAX 相对以往最强的 SOTA 模型平均领先 37.4 个百分
Related stories
UCSB and Microsoft Propose ScholarEvolve for AI Agents to Read Papers and Self-Modify Code
Researchers from UC Santa Barbara and Microsoft introduced ScholarEvolve, a method that automates the research process of reading literature, implementing algorithms, and evaluating results to enable AI agents to evolve their harness code without modifying underlying model parameters. The approach addresses the limitation of prior coding-agent-based harness optimization, which relied on the agent's existing knowledge and observed failures, by allowing agents to draw on the latest academic findings. The paper and code are publicly available.
2 reports · 1 sources
Fudan, Tencent Hunyuan, Tsinghua Release ExplorationBench to Test AI Rule Discovery
Fudan University, Tencent Hunyuan, and Tsinghua University released ExplorationBench, a benchmark measuring how AI systems discover rules in unfamiliar environments. It includes two altered 'alien worlds'—the programming language AlienCode and the logic proof system AlienLogic—where models must learn rules through trial and error. Results showed that without environment feedback, scores remained low (max 11.0%), while autonomous exploration led to high scores (up to 89.0%).
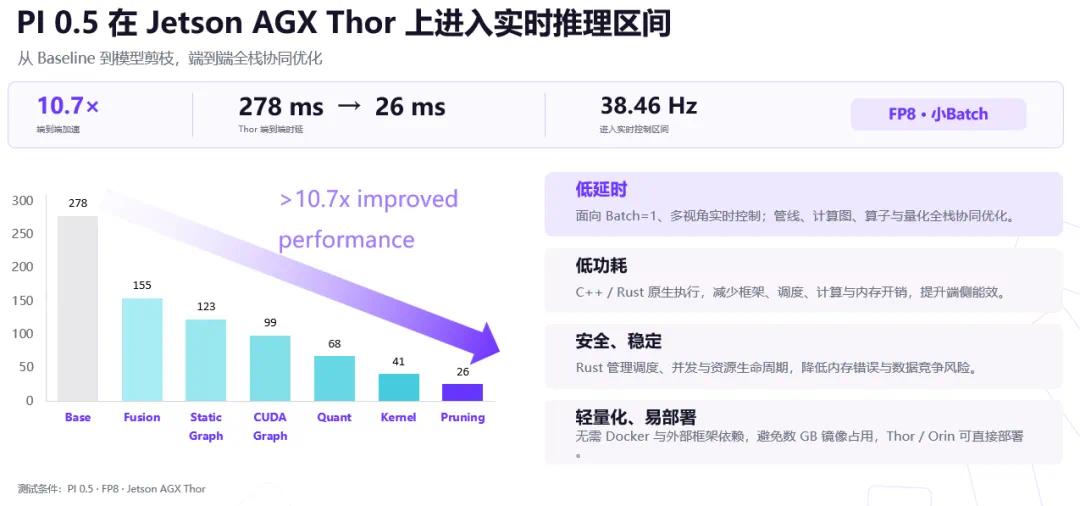
Tsinghua, Infinigence-AI, SJTU Open-Source On-Device Inference Engine APXInf for Embodied Models
On September 15, Tsinghua University, Infinigence-AI, and Shanghai Jiao Tong University open-sourced APXInf, an on-device inference engine for embodied models. The engine reportedly achieves a 10.7x end-to-end speedup on robot hardware, reducing inference latency from 278ms to 26ms on Thor chips with FP8 configuration, enabling real-time control at 38.46Hz.
Stanford's OpenWAM framework isolates design choices in world-action models
Stanford researchers led by Li Fei-Fei, Jiajun Wu, and Ehsan Adeli released OpenWAM, an open framework for composable world-action models, aiming to systematically isolate which design choices drive performance gains. The release follows Black Forest Labs' open-source FLUX 3 Action, a 7B world-action model that surpassed Cosmos 3 Nano on Nvidia's RoboLab-120 leaderboard with less than half the parameters.
News updates every hour. Subscribe in your RSS reader to get new stories automatically.
Subscribe