NVIDIA and collaborators unveil TacitVLA, cutting VLA reasoning latency by up to 3.4x
Researchers from NVIDIA, NYU, UC Berkeley, Johns Hopkins, and Stanford introduced TacitVLA, a vision-language-action model trained to generate reasoning text but whose actions do not wait for it. On four robot manipulation and autonomous driving benchmarks, TacitVLA matched the success rate of explicit-reasoning models while cutting latency by up to 3.4x, and outperformed the same model without reasoning training by up to 17 percentage points at equal speed.
Coverage timeline
机器之心机器之心
本文第一作者为纽约大学计算机科学博士生 Jack Lu,研究工作完成于他在英伟达实习期间。本文由英伟达资深研究科学家、Alpamayo 研究技术负责人 Yan Wang,以及英伟达自动驾驶研究负责人、斯坦福大学副教授 Marco Pavone 共同指导。 如今,许多视觉 - 语言 - 动作(VLA)模型会先推理、再行动。在输出动作之前,模型先写一段简短的文本,比如对场景的描述、一个计划,或者下一步要完成的子任务。这样做的机器人成功率更高,但速度也更慢。推理文本需要逐个 token 自回归地生成,动作必须等文本写完才能开始。在论文的实验中,写推理文本最多占到单次模型调用耗时的 70%。 来自英伟达、纽约大学、UC 伯克利、约翰斯・霍普金斯大学和斯坦福大学的研究团队仔细考察了推理的收益究竟从何而来。他们发现,动作并不需要读取当前这一步写出的推理,模型学会写推理就已经足够。团队据此提出了 TacitVLA。它和标准的推理 VLA 一样被训练去写推理,但它的动作从不等待这段文本。 在机器人操作和自动驾驶的四个 benchmark 上,TacitVLA 的成功率与显式推理相当,延迟最多降低 3.4 倍。在相同速度下,它比不加推理训练的同一模型成功率最多高 17 个百分点。在两个长程记忆 benchmark 上,TacitVLA 还刷新了已发表方法的最好成绩,在 RMBench 上提升 21 个百分点,在 RoboMME 的计数任务上提升 16 个百分点。 论文标题:TacitVLA: Reasoning Vision-Language-Action Models Without Reasoning Latency 论文链接:https://arxiv.org/abs/2610.17540 项目主页:https://tacitvla.github.io/ 推理文本的三种作用 在推理 VLA 中,生成的文本有三种作用。 训练时,它是监督目标。学习写出这段文本,会塑造 action expert 所依赖的 backbone。 在长程任务中,它还可以充当记忆。假设机器人需要按好几次按钮,摄像头拍不出已经按了几次,但一份记录已完成子任务的日志可以。 最后,在部署时,文本是 action expert 的输入。action expert 要读取当前这一步写出的文本,所以动作必须等待。Ta
Related stories
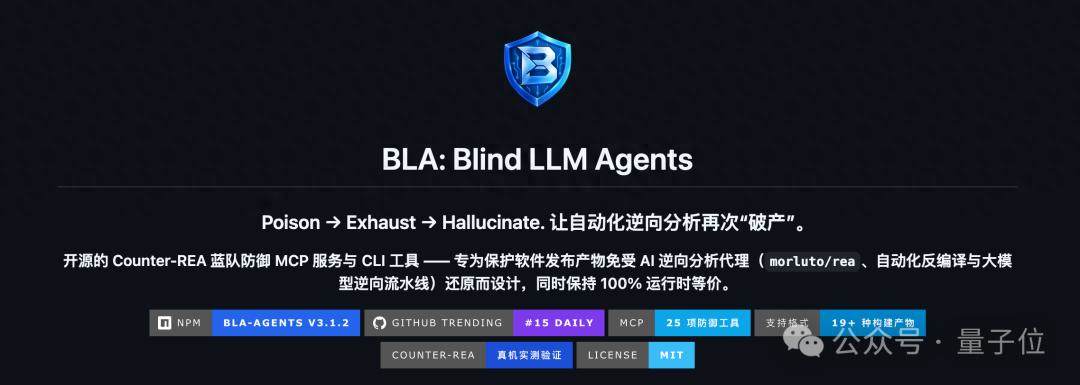
Undergrad's BLA tool poisons code to inflate AI reverse-engineering token costs 300-2800x
A Sun Yat-sen University undergraduate released BLA, an anti-REA tool that poisons code to inflate AI reverse-engineering token costs by 300-2800x. The tool uses three tactics: poisoning files with fake credentials and decoy source maps, exhausting analyzer quotas, and inducing misjudgment. It has gained over 3,900 GitHub stars and 476 forks.
1 reports · 1 sources
RAX: Harvard, Berkeley, NVIDIA Introduce Online Exploration Scaling for Robot Learning, Outperforming SOTA by 37.4 Points on Average
Researchers from Harvard, NVIDIA, UC Berkeley, MIT, and Stanford proposed RAX (Robot Agent eXploration), which introduces scaling online exploration to robot learning. RAX uses a general coding agent to connect directly to a robot's perception and control interfaces, enabling the robot to gain experience through exploration and write successful decisions as executable programs, accumulating reusable skills. With frozen model parameters, RAX outperforms previous state-of-the-art models by an average of 37.4 percentage points across five simulation benchmarks: RoboDojo, BEHAVIOR-1K, HumanoidArena, DexJoCo, and LIBERO-Pro.
1 reports · 1 sources
UCSB and Microsoft Propose ScholarEvolve for AI Agents to Read Papers and Self-Modify Code
Researchers from UC Santa Barbara and Microsoft introduced ScholarEvolve, a method that automates the research process of reading literature, implementing algorithms, and evaluating results to enable AI agents to evolve their harness code without modifying underlying model parameters. The approach addresses the limitation of prior coding-agent-based harness optimization, which relied on the agent's existing knowledge and observed failures, by allowing agents to draw on the latest academic findings. The paper and code are publicly available.
RAVEL: Training-Free Method Improves Vision Encoder Evaluation for Multimodal LLMs
Researchers proposed RAVEL, a training-free evaluation method with two improvements—stabilized PCA whitening and patch-level similarity scoring—to predict how well vision encoders perform in multimodal LLMs. Experiments on 210 multimodal LLMs showed existing cross-modal methods degrade as candidate pools grow, while RAVEL achieved an average Spearman correlation of 0.85, outperforming prior methods by up to 101.1%.
News updates every hour. Subscribe in your RSS reader to get new stories automatically.
Subscribe